Foot Pedal
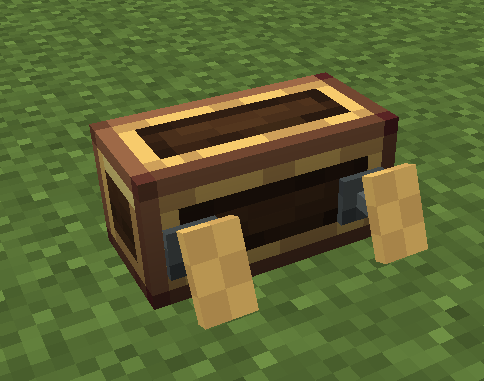
The Foot Pedal installs a pair of pedals (left and right) onto a Control Desk. While you sit on a linked seat in operation mode, holding a pedal's press key pushes the pedal down (it translates forward, +z), holding the lift key raises it (-z), and releasing both returns it to the middle.
Pedal travel is analog — pressing is a smooth ramp to full deflection, not a step.
Default Keys
| Pedal | Press down | Lift up |
|---|---|---|
| Left | Q |
E |
| Right | E |
Q |
The four key bindings are configurable per-desk in the module settings menu (open the desk config menu and click the "Foot Pedal" row).
Module Settings
- Return time (ticks, default 2, range 0..100, shared by both pedals) — how long a released pedal takes to return to the middle;
0disables returning (the pedal stays where it is). - Full-deflection time (ticks, default 2, range 1..100, shared) — how long holding the press/lift key takes to reach full travel (smaller = faster). 20 ticks = 1 second.
Lua API
local ss = require("ccpe.sensor_system")
local desk = ss.getPeripheral(4)
local pedal = desk.getModule("pedal")   -- nil if no pedal installed
pedal.getLeftPedal() / pedal.getRightPedal()
Returns the pedal's analog position (number, -1..1): +1 = fully pressed down, -1 = fully lifted, 0 = middle.
pedal.getPedalDifference()
Returns the difference between the two pedals (number, -2..2): right − left. Positive = right pedal pressed deeper; negative = left pedal pressed deeper.
pedal.isLeftPedalDown() / pedal.isRightPedalDown()
Returns true while the pedal is on the pressed side (axis value > 0, including the remaining travel while returning).
pedal.isLeftPedalUp() / pedal.isRightPedalUp()
Returns true while the pedal is on the lifted side (axis value < 0).
All methods are mainThread = false — safe to poll in a loop on the computer.
Example: Differential Pedals
A classic use for a pedal pair is a differential throttle: the average of both pedals is the overall throttle, and getPedalDifference() is the turning amount.
local ss = require("ccpe.sensor_system")
local desk = ss.getPeripheral(4)
local pedal = desk.getModule("pedal")

while true do
    local left, right = pedal.getLeftPedal(), pedal.getRightPedal()
    local throttle = (left + right) / 2          -- -1..1, overall forward/back
    local turn     = pedal.getPedalDifference()  -- -2..2, right minus left
    print(("throttle %.2f  turn %.2f"):format(throttle, turn))
    os.sleep(0.05)
end