Throttle 2
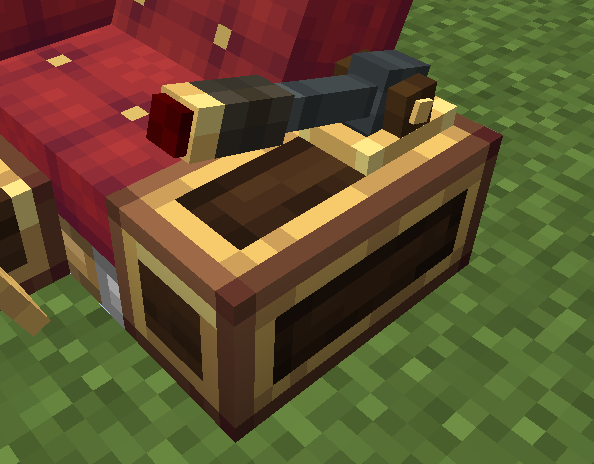
The Throttle 2 installs onto a Control Desk and is a collective lever: the handle rotates around its pivot (model-space (4,2,8)) instead of sliding. Its angle is continuous, ranging from 0° (bottom, as placed) to +30° (full pull-up).
It occupies the full 14×6 desk-top grid — the only legal placement is center
(8,12)with 0°/180° rotation only — so it is mutually exclusive with the Throttle and Monitor 2 (only one of them can be installed at a time).
Angle Control
- Hold the pull-up key (default
Space) to raise the handle (angle +); hold the pull-down key (defaultLeft Ctrl) to lower it (angle −). - Full-deflection time (ticks): how long you must hold a key to reach the full +30° — default 20, range 1..100 (20 ticks = 1 second). While held, the angle advances by
30° / full-deflection-timeeach tick. - When no key is held, the behavior depends on the return switch:
- Return off (default): the handle locks in place — like a mechanical collective, it stays where it is (latch, no auto-return).
- Return on: the handle returns to the neutral 15° (half of 30°) at the return time rate — default 2 ticks, range 0..100 (
0= return disabled).
Key Bindings
| Action | Default key |
|---|---|
| Pull up (angle +) | Space |
| Pull down (angle −) | Left Ctrl |
Both bindings, the full-deflection time and the return switch/time are configurable per-desk in the module settings menu (open the desk config menu and click the "Throttle 2" row). They are independent from the regular Throttle bindings — both controls can be installed on different desks and configured separately.
Lua API
local ss = require("ccpe.sensor_system")
local desk = ss.getPeripheral(4)
local th2 = desk.getModule("throttle_2")   -- nil if no throttle 2 installed
th2.getAxis()
Returns the normalized lever position (number, 0..1) = angle / 30°: 0 = bottom (as placed), 1 = full pull-up.
th2.getCenterAxis()
Returns the lever position relative to the neutral 15° (number, -1..1) = (angle − 15°) / 15°: -1 = bottom (0°), 0 = neutral (15°, the resting point in return mode), +1 = full pull-up (30°). Most useful when the return switch is on.
th2.setAngle(degrees)
Directly sets the lever angle (degrees, 0..30, out-of-range values are clamped). Runs on the main thread (mainThread = true) and writes the server-authoritative angle, then broadcasts it.
Note: while a player is operating the desk from a linked seat (input lease active), the server simulation advances the angle every tick and overrides this call. With no player input (return off = latch), the setting persists until the next key press / return.
All read methods are mainThread = false — safe to poll at high frequency.