Joystick
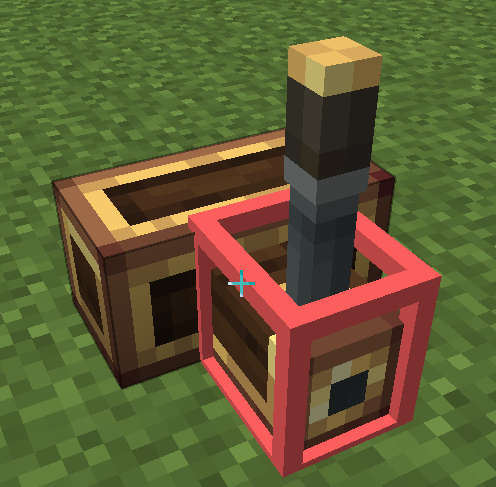
The Joystick installs onto a Control Desk and tilts up to 15° in any direction: push forward (default W), pull back (S), tilt left (A) or right (D). Release the keys and it returns to the center.
Deflection Modes
Each axis (forward/back, left/right) is configured independently:
- Free mode (default): the stick deflects smoothly. Full-deflection time (ticks) controls how long holding a key takes to reach full tilt (default 2, range 1..100); return time (ticks) controls how long it takes to return to the center after release (default 2, range 0..100;
0= no return — the stick stays where it is). 20 ticks = 1 second. - Gear mode: the stick snaps to discrete gear positions instead of deflecting smoothly. Gear count: 1..31 (default 4). Gear positions are evenly spaced from -1 to +1 (e.g. 4 gears →
{-1, -1/3, +1/3, +1}; 3 gears →{-1, 0, +1}; 2 gears →{-1, +1}). Each press of a key steps one gear up/down (holding does not repeat), and there is no auto-return — the stick stays on its gear even after you leave the seat, like a physical gear lever.
Key Bindings
| Direction | Default key |
|---|---|
| Forward / Back | W / S |
| Left / Right | A / D |
All four bindings are configurable per-desk in the module settings menu (open the desk config menu and click the "Joystick" row).
Lua API
local ss = require("ccpe.sensor_system")
local desk = ss.getPeripheral(4)
local joy = desk.getModule("joystick")   -- nil if no joystick installed
joy.isAxisXActive() / joy.isAxisYActive()
Returns true while any key of that axis is pressed (X = left/right, Y = forward/back).
joy.getAxisX() / joy.getAxisY()
Returns the axis magnitude (number, 0..1) — how far the stick is deflected on that axis, regardless of direction.
joy.getAxisXSigned() / joy.getAxisYSigned()
Returns the signed axis value (number, -1..1): +1 = right (D) / forward (W), -1 = left (A) / backward (S).
All methods are mainThread = false — safe to poll at high frequency.
Example
local ss = require("ccpe.sensor_system")
local desk = ss.getPeripheral(4)
local joy = desk.getModule("joystick")

while true do
    local forward = joy.getAxisYSigned()  -- -1..1, thrust amount
    local steer   = joy.getAxisXSigned()  -- -1..1, turning amount
    print(("forward %.2f  steer %.2f"):format(forward, steer))
    os.sleep(0.05)
end